Benchmark • generative AI • 3D simulation
Robotic Hand Benchmark
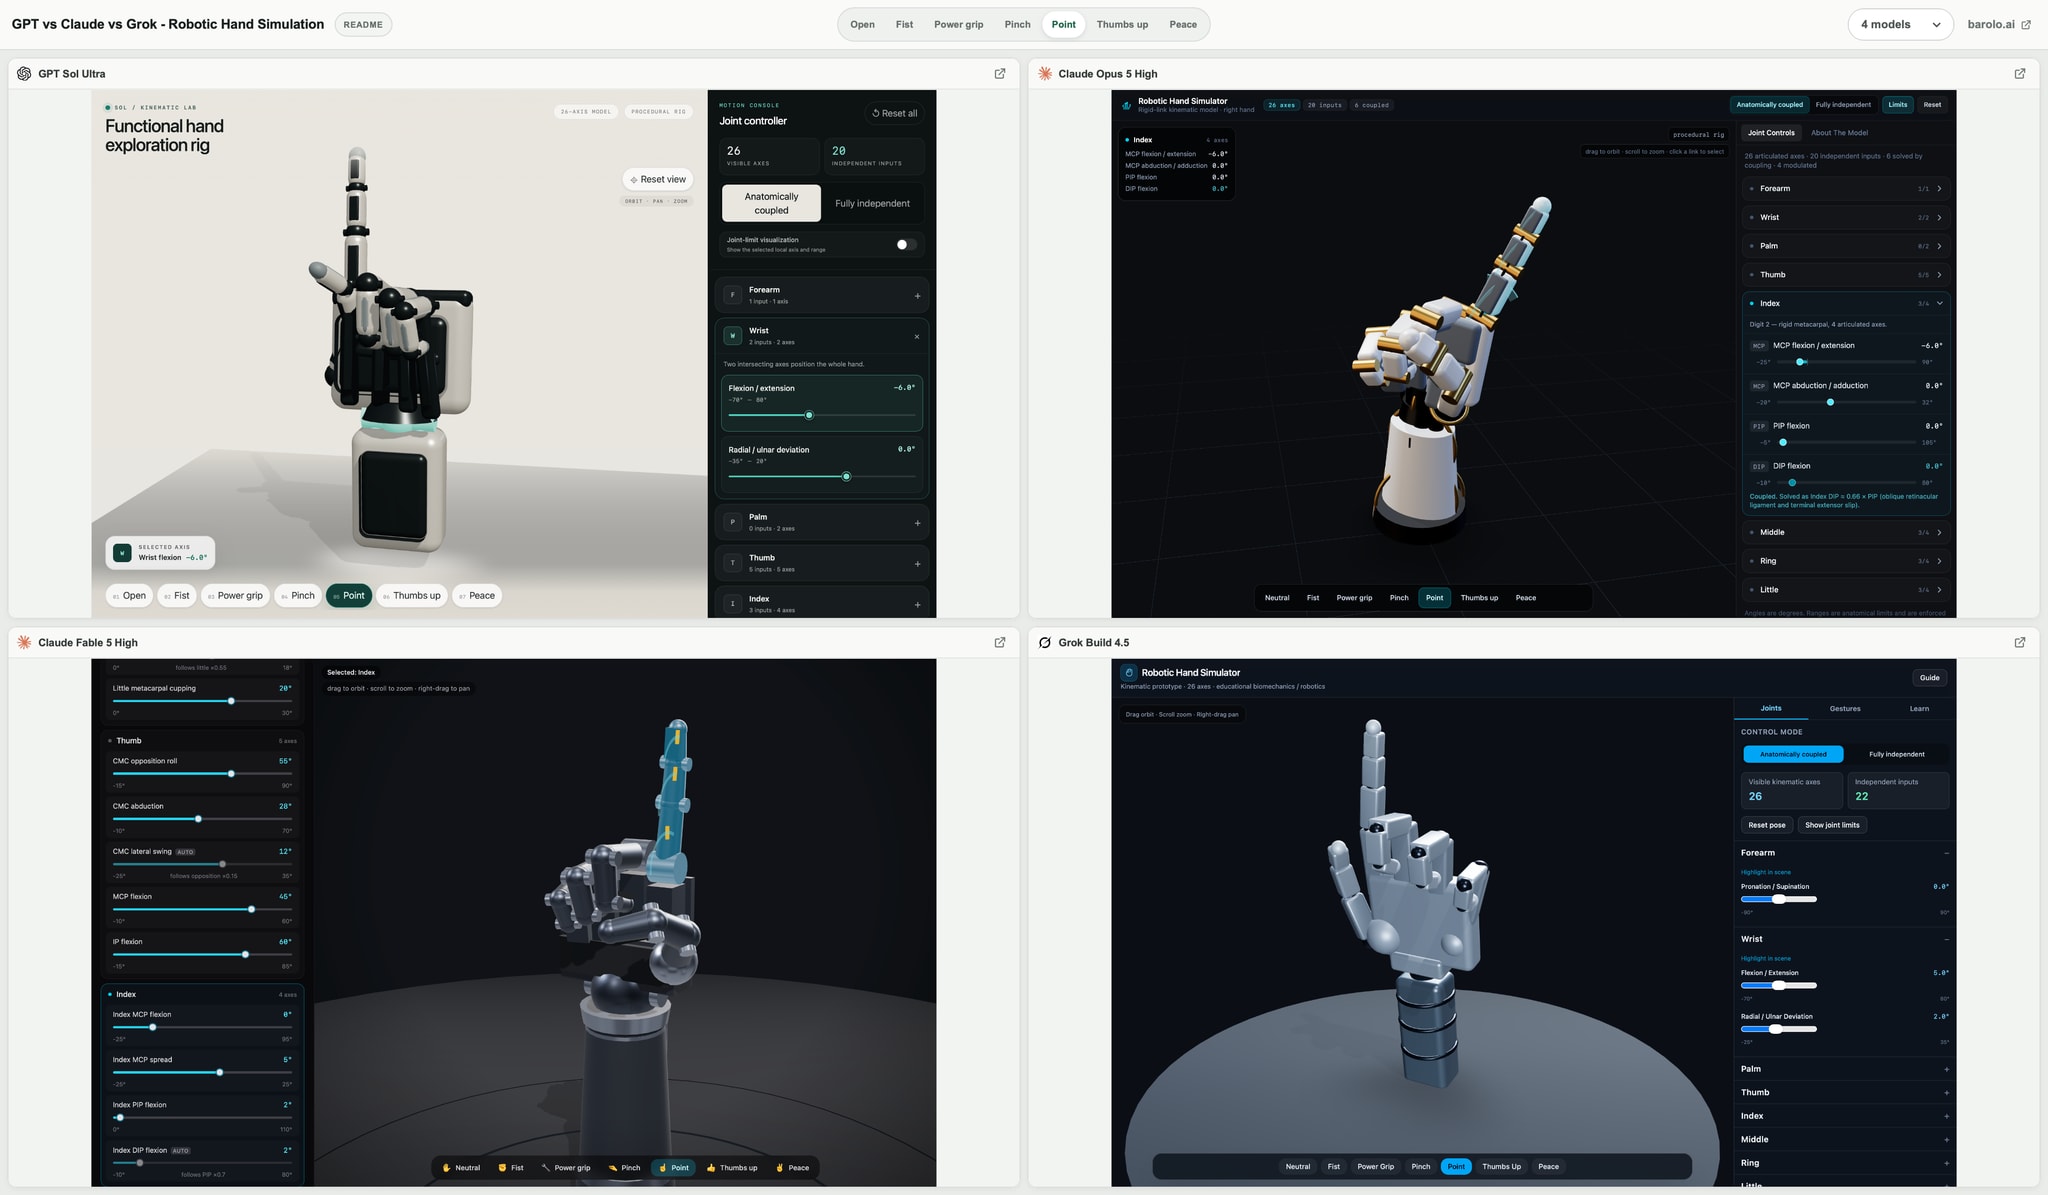
This project explores how well AI coding models can generate complex 3D models and physics simulations from a single prompt. I built a benchmark comparing nine model configurations from OpenAI, Anthropic, and xAI, each tasked with creating an interactive robotic hand. Their outputs run side by side, allowing direct comparison of geometry, joint articulation, movement, and usability through shared gesture controls. The goal was to test the limits of one-shot generation: could each model translate a detailed brief into a convincing, functional simulation? Preserving the original outputs makes differences in spatial reasoning, implementation quality, and physical realism easier to assess.